Our development work

Inside our development work.

Our development foundation spans the G1 console, cloud administration, document knowledge and voice. These examples are project references; each new customer deployment has its own scope and acceptance.

Engineer examining and repairing an electronic circuit board
Application development

A connected G1 software foundation.

Development progressed from a local robot console into cloud administration, document knowledge, Gemini conversations and robot voice-session management.

The work connects customer setup with the robot application and gives an operator a clearer view of the session lifecycle.

FocusUnitree G1 application development
ComponentsCustomer knowledge, voice, session controls and usage
EvidenceImplemented software and development records; each customer deployment requires its own acceptance.
kinbotix / operator workspace
Sample workspace
◈   Overview▤   Knowledge◉   Sessions▥   Usage
Ready for the next event.
Showcase profile · Demonstration content
01Robot profile
03Knowledge files
12Sample sessions
Customer knowledge
▤
Product introduction.pdf
Approved event information
Ready
▤
Visitor questions.pdf
Customer-specific answers
Ready

Illustrative interface representing the application workflow.

Explore the interactive preview
Engineering foundation

Understanding the robot’s state.

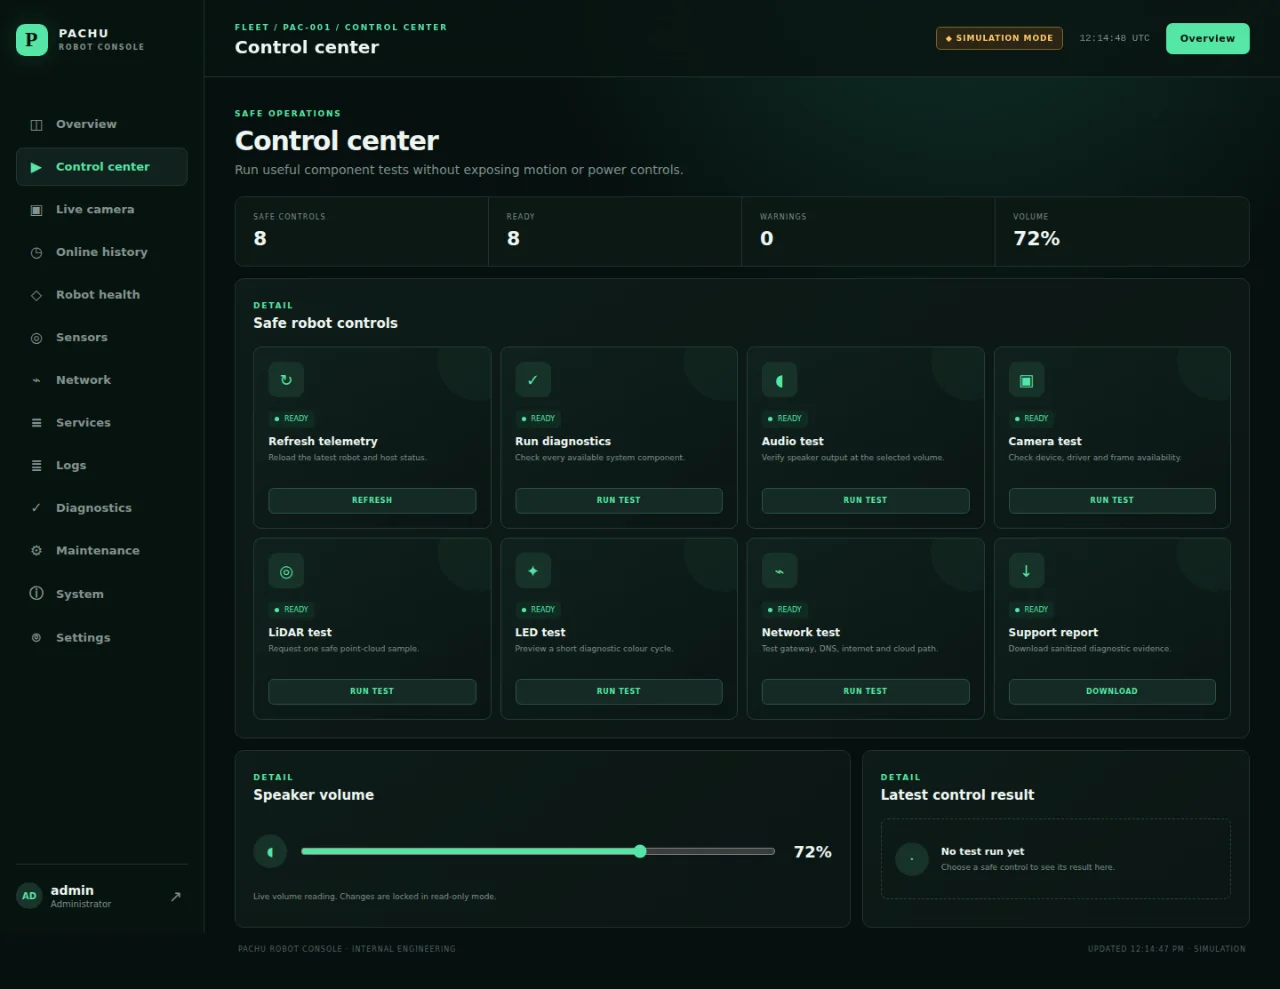
The local console work brings diagnostics, application services and telemetry interfaces into a browser workflow. It forms part of the practical engineering foundation for connected applications.

FocusLocal visibility and application diagnostics
ComponentsConsole, robot bridge, service status and camera pathways
ApplicationA starting point for project-specific operator and engineering tools
Pachu console control centre in simulation mode with diagnostics and application controls
Control centre · simulation mode · Developer project reference
Research & simulation

Exploring gesture and movement.

Motion work includes pose preparation, retargeting, gesture keyframes and simulation experiments. It explores how a desired movement can be represented and evaluated for a humanoid.

Offline previews and simulated results are development evidence. Physical execution remains a separate engineering and validation milestone.

FocusMotion preparation and evaluation
ToolsPose data, keyframes, retargeting and MuJoCo experiments
StatusResearch and offline development; custom physical dance is not offered as a validated ready-made product.
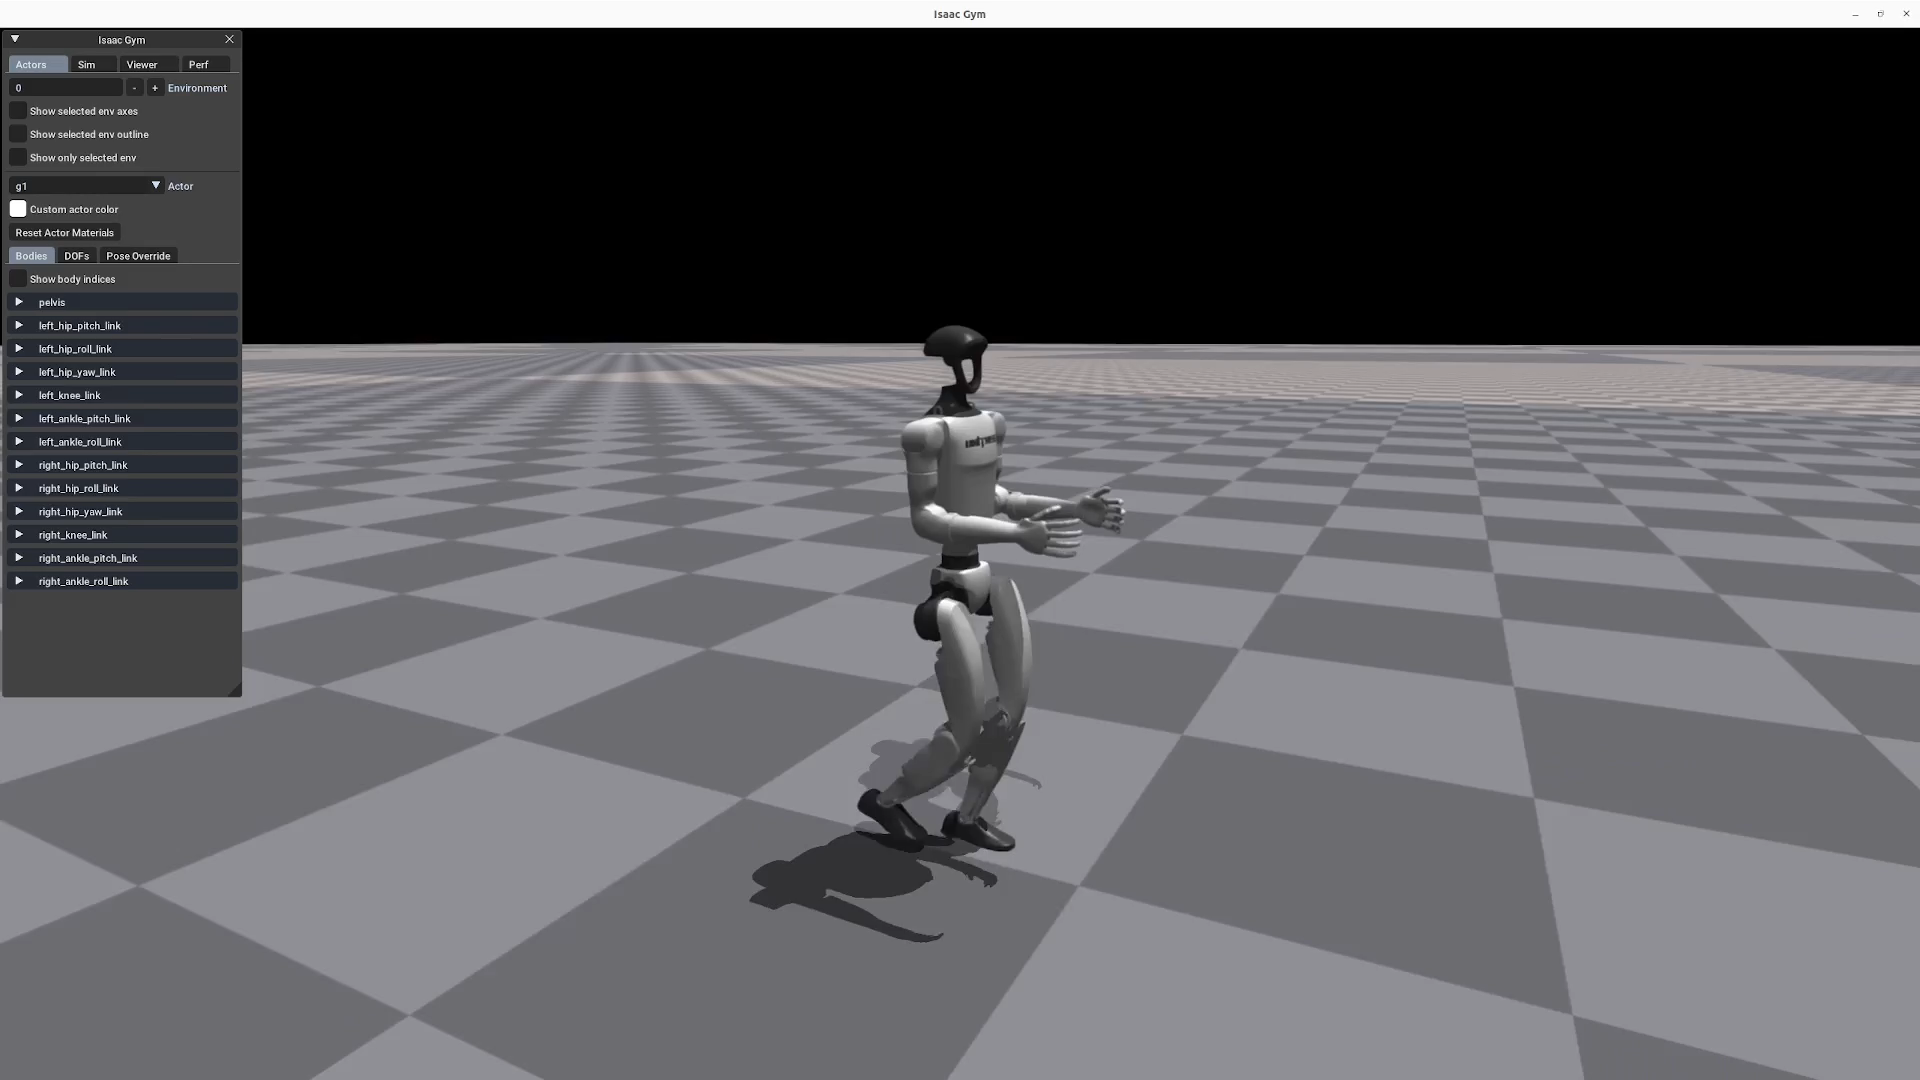
G1 humanoid simulationIsaac GymOpen video ↗

Source: Unitree Robotics · RL Gym. Official simulation reference.

Video loads from Unitree when you press play.

Official Unitree simulation reference. Kinbotix motion-development work is described alongside it; this is manufacturer footage.

Explore simulation and prototyping
Project reference / Rentobots

When a robot meets an audience.

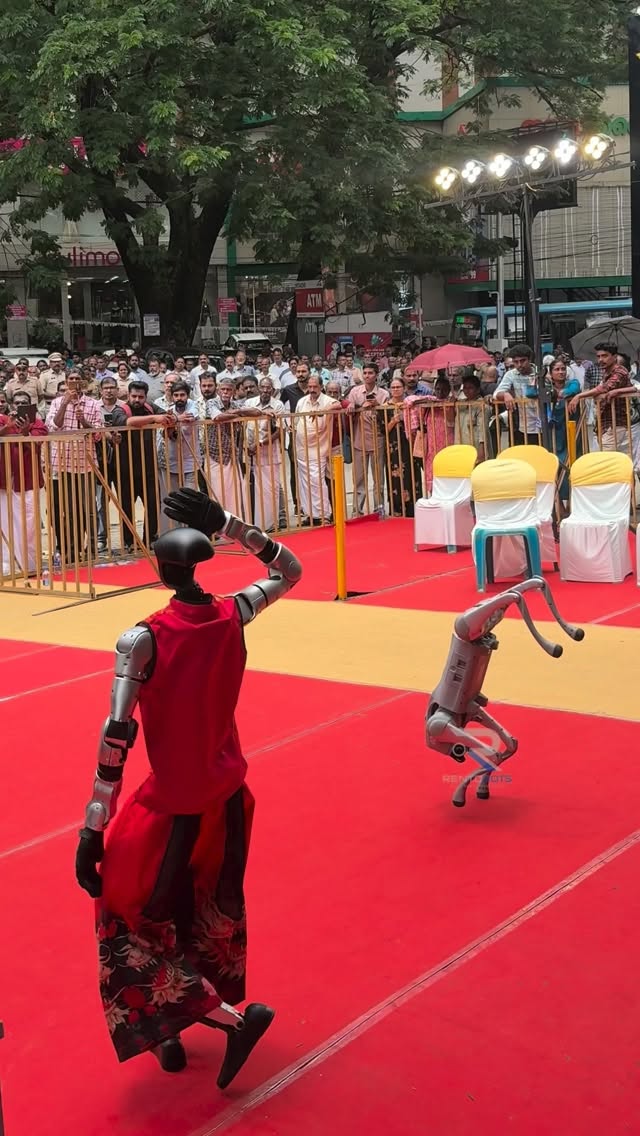
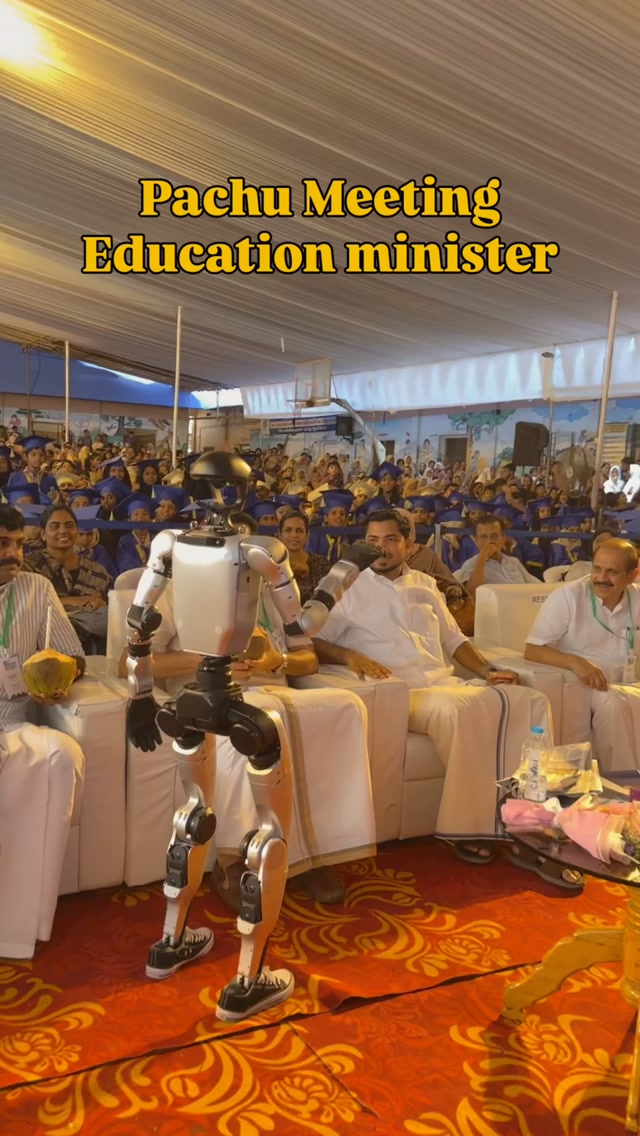
These public Rentobots posts show Pachu interactions at events, providing context for earlier development work and the audiences a robot application can serve.

Follow @rento_bots

Original posts by Rentobots. Shared as an attributed development reference; they do not represent a Kinbotix Dubai deployment.

Start with a conversation

Bring a specific challenge. Build on the foundation.

We can assess a defined application, integration or simulation brief and agree the next development milestone.

Discuss your project

A defined first milestone. Clear acceptance criteria. Support that fits.